WIM Open-Sources the Drive Layer of PLEM, Its Robot Control Platform
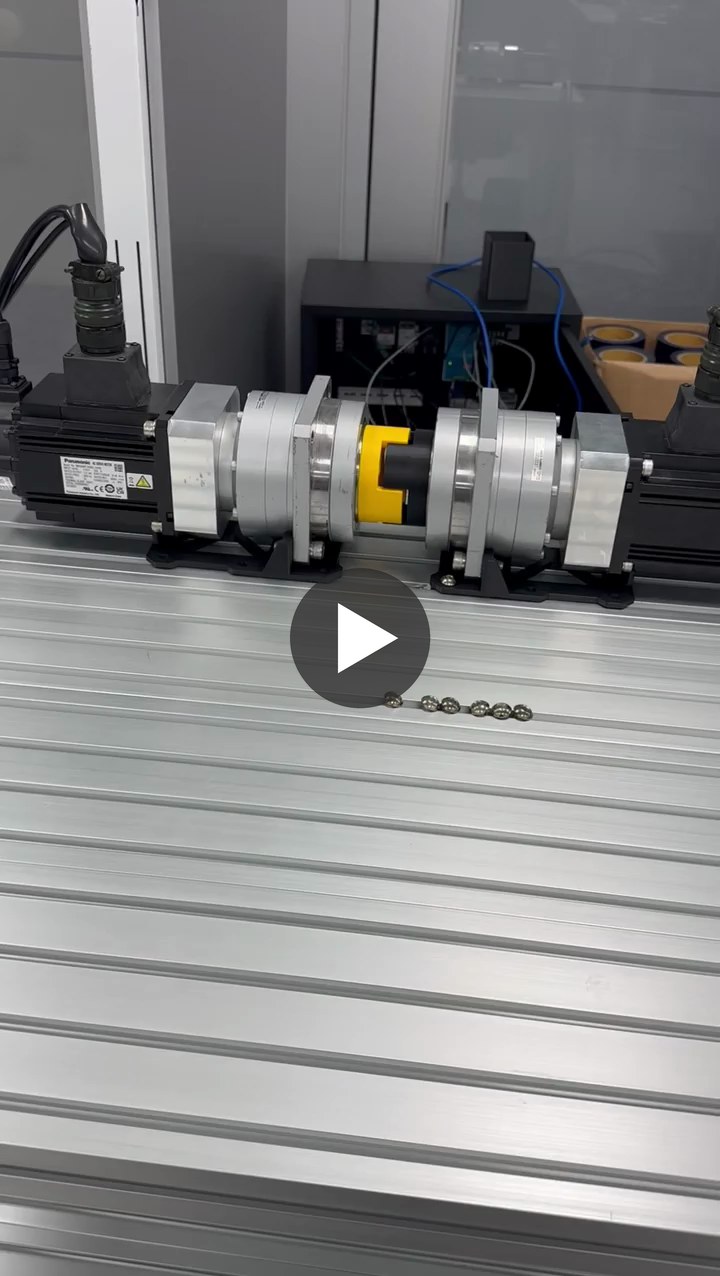
WIM has open-sourced the drive layer of PLEM, its robot control platform. The code is available to everyone under the Apache 2.0 license in the GitHub repository WIM-Corporation/PLEM.
The drive layer runs EtherCAT servo drives in real time from an NVIDIA Jetson. You describe a bus and its drives in one YAML file, and it runs under ros2_control on a real-time loop. You write no C++, and you move the axes from Python or from any ROS 2 client. A setup wizard for the real-time kernel, CPU isolation and the EtherCAT master is included.
The first public release (v0.11.0) supports Jetson AGX Orin, JetPack 7.2.1 and ROS 2 Jazzy. It ships with a two-axis servo example and installation docs, so anyone with a Jetson and EtherCAT drives can follow along and run it.
WIM is building the Android of robotics: the layers that make a robot move, from the real-time OS to low-level control, running on Jetson. This release opens the lowest of those layers to developers and researchers as a first step.