WIM CONTROL Module
Control-Ready Robot Controller · Based on NVIDIA® Jetson AGX Orin™ 64GB
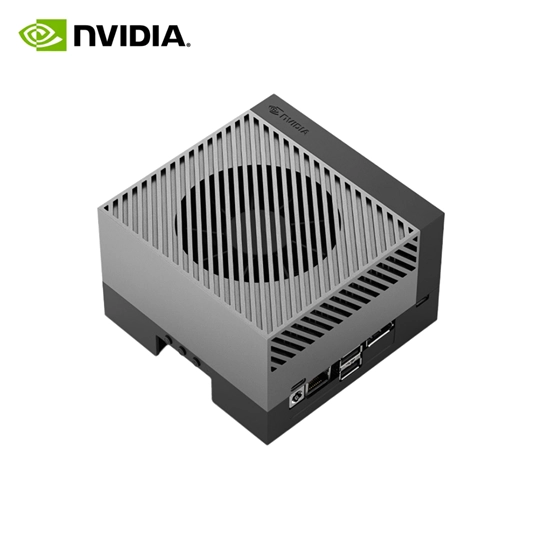
NVIDIA Jetson AGX Orin Developer Kit
Product photos: NVIDIA Jetson AGX Orin Developer Kit (NVIDIA Corporation)
Main Features
- NVIDIA Jetson AGX Orin 64GB
- 12-core Arm Cortex-A78AE, 275 TOPS
- PREEMPT_RT kernel · CPU isolation tuning
- 1 ms (1 kHz) control cycle, p99 jitter 0.7–1.2 µs
- IgH EtherCAT Master
- EtherCAT NIC, 2-port / 4-port
- CiA 402 servo drive control (CSP / CSV / CST)
- 24 axes verified simultaneously
- WIM_CONTROL SDK (C++ / ROS 2)
- ROS 2 Humble / Jazzy
- NVMe SSD 512GB / 1TB
From ₩5,750,000
excl. VAT · Prices as of October 2026
Overview
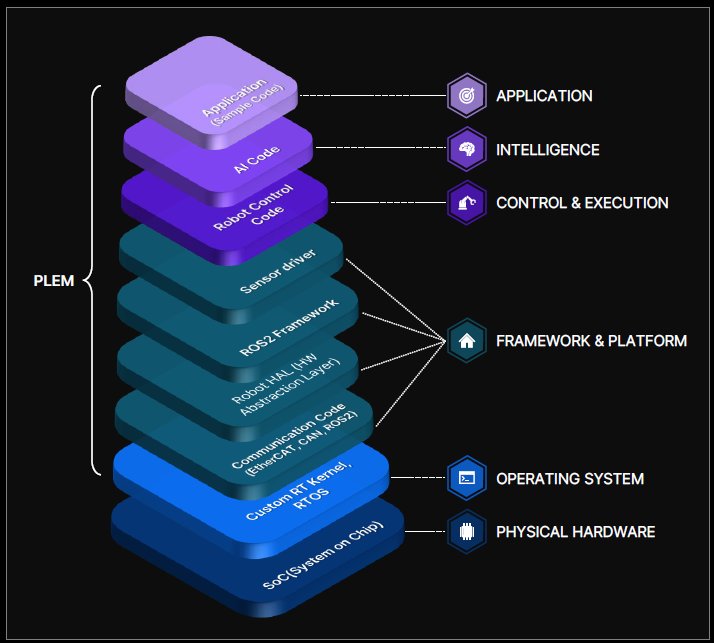
WIM CONTROL Module is a Control-Ready robot controller: an NVIDIA Jetson AGX Orin 64GB Developer Kit shipped with a real-time robot control environment installed and tuned. The PREEMPT_RT kernel, CPU isolation, IgH EtherCAT master and WIM_CONTROL SDK arrive installed and inspected, so you can drive EtherCAT servo motors at a 1 ms (1 kHz) cycle right after power-on. It suits control development for humanoids and AMRs, manipulator research in university labs, and evaluation of AI-based robot applications.
The hardware is built around the Jetson AGX Orin module: a 12-core Arm Cortex-A78AE CPU, an NVIDIA Ampere GPU and 64GB of LPDDR5 Unified Memory shared by CPU and GPU, delivering up to 275 TOPS (Sparse INT8) of AI compute. The control loop runs on isolated CPU cores while the GPU handles vision/AI inference.
Real-time performance is secured at the kernel level. A PREEMPT_RT kernel is combined with dedicated control-core isolation, IRQ separation, fixed clocks and disabled deep C-states, and a p99 cycle jitter of 0.7–1.2 µs was measured in live EtherCAT operation at a 1 ms control cycle*. EtherCAT runs at 1 kHz on a PCIe NIC bound to the native driver, while the onboard 10GbE is kept for development and networking.
Motor control is handled by the WIM_CONTROL SDK. Its drive tier drives CiA 402 servo drives from a YAML declaration alone, without a robot model, with CSP, CSV or CST selectable per axis. Control functions are provided through ROS 2 actions, services and topics, and torque controller plugins can be developed in C++.
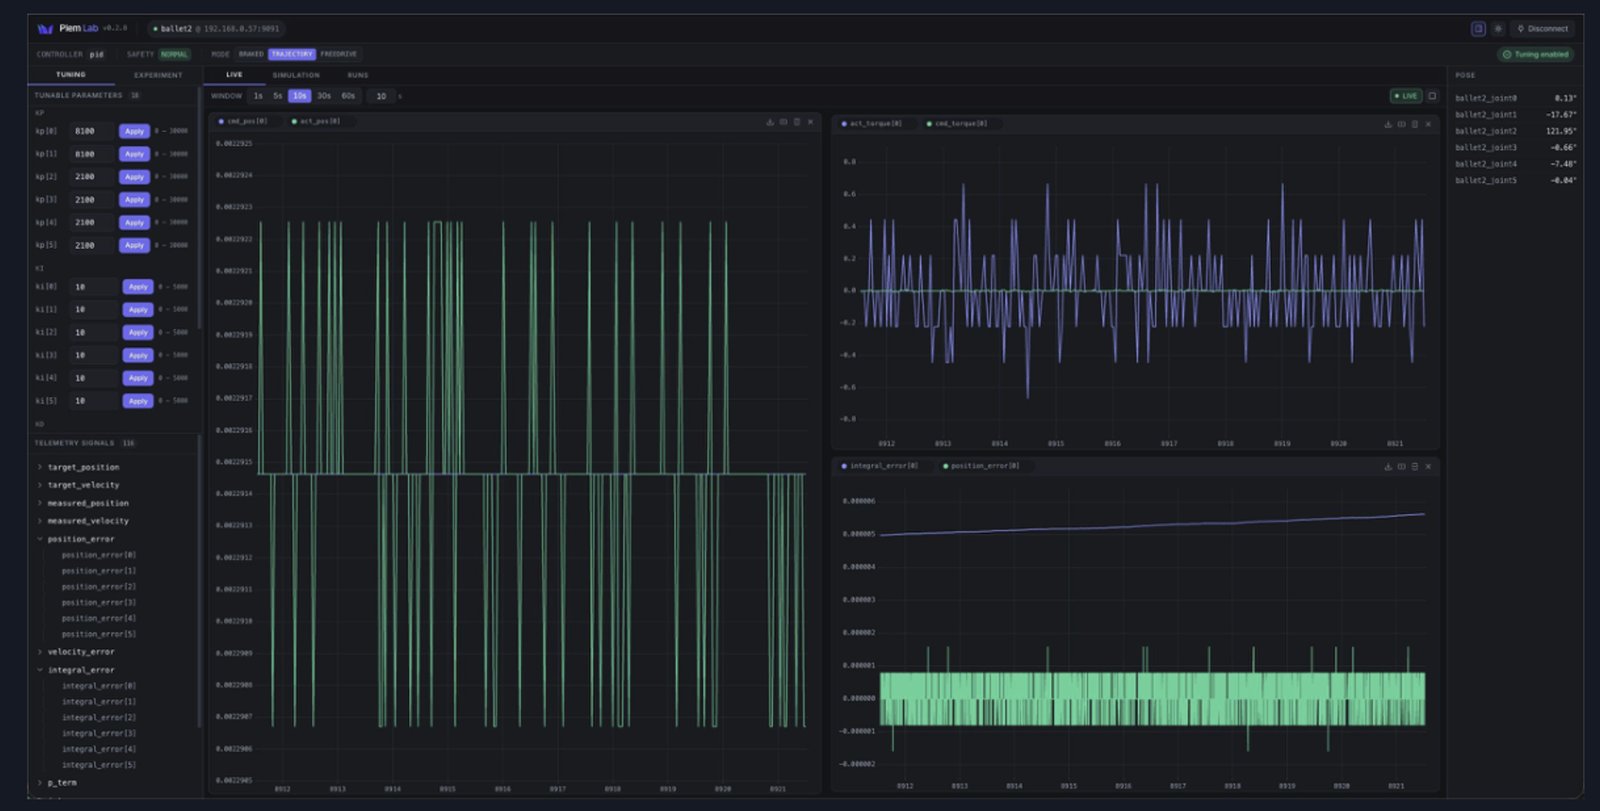
* Jitter measured in live EtherCAT operation (Panasonic MINAS A6B, 2 axes CSP, 1 ms, zero cycle loss). See the datasheet for test conditions.
Specifications
HARDWARE
- CPU Support
- NVIDIA Jetson AGX Orin 64GB: 12-core Arm Cortex-A78AE 64-bit, up to 2.2 GHz
- GPU Support
- NVIDIA Ampere architecture GPU (with Tensor Cores)Up to 275 TOPS (Sparse INT8)
- Memory
- 64GB LPDDR5 (CPU · GPU Unified Memory)
- Storage
- 64GB onboard eMMCNVMe SSD 512GB / 1TB (optional, factory-installed)
- Ethernet
- 1 × RJ45 10GbE (development · networking)EtherCAT NIC 2-port / 4-port (optional, PCIe, EtherCAT only)
- I/O
- USB × 6 (Type-C 2 · Type-A 4)1 × DisplayPortPCIe expansion slot
- Wireless
- Wi-Fi 5 (802.11ac)
- Power Requirement
- USB Type-C power adapter (19 V) includedPower consumption 15 – 60 W (MAXN mode excluded)
- Dimensions
- 110 × 110 × 71.65 mm / 872.5 g
REAL-TIME
- OS
- JetPack 6JetPack 7
- RT Kernel
- PREEMPT_RT real-time kernel · dedicated core isolation for a guaranteed control cycle
- Control Cycle
- 1 ms (1 kHz)p99 cycle jitter 0.7–1.2 µs*
ETHERCAT MOTION CONTROL
- EtherCAT Master
- IgH EtherCAT MasterNative NIC driver, 1 kHz operation
- Drive Profile
- CiA 402 (CoE)CSP / CSV / CST, selectable per axis · mixed on one busSM sync · DC SYNC0
- Axes
- 24 axes simultaneous control (verified on four 6-axis robots)Drive tier: 1 – 8 axes per bus
- Safety Functions
- Position · velocity · torque limits must be declared per axisProtective stop and brake engagement on limit violation or a 100 ms command gapMotion refused until bench check · approval
- Protocols
- EtherCAT
* Jitter measured in live EtherCAT operation (Panasonic MINAS A6B, 2 axes CSP, 1 ms, zero cycle loss). Hardware items follow the official NVIDIA Jetson AGX Orin Developer Kit specifications.
Software
WIM_CONTROL SDK
- Packages
- RT control core · EtherCAT fieldbus · IPCCiA 402 drive tierROS 2 messages · services · actionsREST API · job runnerWeb teaching pendant · Lab toolTerminal UICoding agentDevice registration · license
- C++ API
- Torque controller plugin SDK
- ROS 2
- Humble / JazzyControl · status interfaces
MOTION · AI · TOOLS
- Control Modes
- Gravity compensation · collision detection · free drive
- Motion Planning
- Built-in PILZ motion planner (other planners can be added)
- Supported Robots
- Neuromeka Indy7 series · Huayan Robotics · FAIRINODirect CiA 402 servo configurationsGrippers OnRobot · DH; cameras ZED · RealSense
- Development
- C++CUDA · TensorRT
MOTOR CONTROL EXAMPLE · drive.yaml
# Panasonic MINAS A6B example, based on a6b_csp_2axis.yaml (excerpt)
# Omitted: PDO mapping · unit conversion · zero offset · stop deceleration · approval record
schema: cia402_drive/v1
bus: { cycle_time_ns: 1000000, sync_mode: sm }
slaves:
  - ring_position: 0
    vendor_id: 0x0000066f        # Panasonic
    product_code: 0x60380009     # MINAS A6B
    axes:
      - name: axis0
        mode: csp                # csp | csv | cst
        limits:                  # required, no defaults
          position: { min_rad: -1250.0, max_rad: 1250.0 }
          velocity_rad_s: 418.0
WORKFLOW
1  check     # schema · slave check
2  bench     # bench check
3  approve   # approve → motion allowed
4  monitor   # status · jitter
Hardware-verified drive
Panasonic MINAS A6B, 2 axes CSP, 1 ms, zero cycle loss, p99 cycle jitter 0.7–1.2 µs
Ordering Information
WIM CONTROL Module
NVIDIA Jetson AGX Orin 64GB · PREEMPT_RT kernel · IgH EtherCAT · WIM_CONTROL SDK preinstalled
Package Contents
- Jetson AGX Orin 64GB module (with thermal solution) · carrier board · Wi-Fi module1
- USB Type-C power adapter (19 V) · power cable · Type-C to A cable1
- NVMe SSD · EtherCAT NIC (selected options, factory-installed)1
- Quick start guide1
Lead Time · Returns
- Lead time: within 2 weeks of order confirmation
- Initial defects: replaced with the same product if reported within 7 days of receipt
- Change of mind: unopened units within 7 days of receipt; round-trip shipping paid by customer
- Built to order; no change-of-mind returns after opening or power-on
For the cabinet type (with I/O, emergency stop and wiring), see W-RC. WIM Robot Controller
FAQ
How is it different from a standard Jetson AGX Orin Developer Kit?+
The hardware is the same. We install the PREEMPT_RT kernel with CPU isolation tuning, the IgH EtherCAT master and the WIM_CONTROL SDK, fit the SSD and EtherCAT NIC, and ship it after inspection.
Which servo drives can I connect?+
EtherCAT servo drives that follow the CiA 402 profile. Declare vendor_id, product_code, PDO mapping and per-axis limits in YAML, then run check → bench → approve. The hardware-verified drive is the Panasonic MINAS A6B; tell us your model when requesting a quote and we will check it.
Which robots can it control?+
Registered manipulators (Neuromeka Indy7 series, Huayan Robotics, FAIRINO) run on the manipulator stack; other EtherCAT (CiA 402) motor setups, including humanoids and mobile robots, run on the drive tier.
Can I run EtherCAT on the onboard 10GbE port?+
The onboard port uses the generic driver and is recommended for evaluation only. For 1 kHz operation, use the EtherCAT NIC ports bound to the native driver.
Does it work on sites without internet?+
The license is verified offline on the device, so it boots without internet. Installation and updates require an internet connection.
Does it support JetPack 7 or Jetson Thor?+
An Ubuntu 24.04 (JetPack 7) configuration is available. For Jetson Thor support, please contact us separately.
Request a Quote
NVIDIA, Jetson and Jetson AGX Orin are trademarks of NVIDIA Corporation.