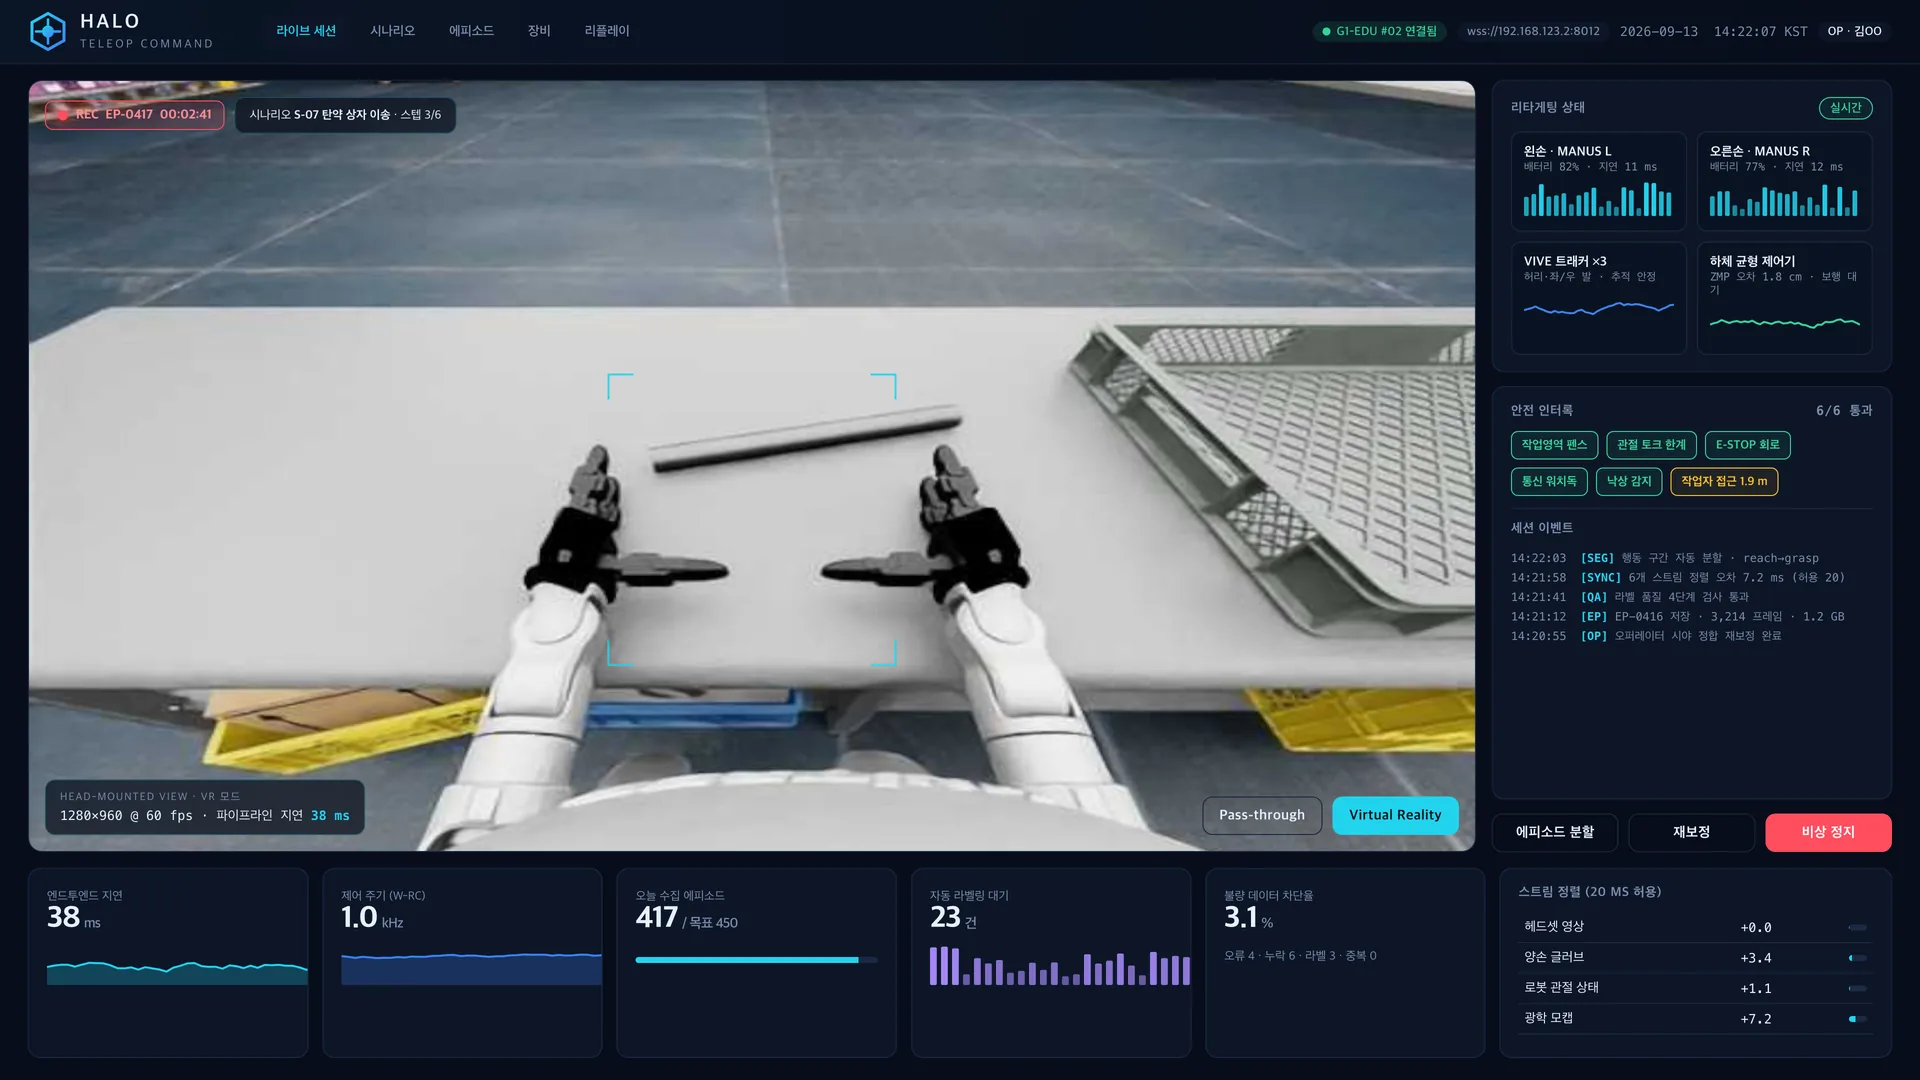
Overview
A console that monitors latency, synchronization, and safety in real time while collecting upper-body motion from a biped via VR teleoperation.
Project Background & Purpose
The customer retargets an operator's upper body to the robot using haptic gloves, 6-DoF trackers, and optical mocap to collect training episodes. Latency and alignment errors used to be checked only after a session, so discard rates were high, and worker-proximity warnings and the emergency stop lived outside the console. The project put a real-time controller in the teleop station to aggregate and supervise lower-level devices at 1 kHz and pass every episode through a four-stage quality gate on save. Walking and balance stay with the robot's built-in controller; the cell integrator owns the risk assessment, including falls, and the stop circuits.
Components
- VR headset, haptic gloves, 6-DoF trackers, optical mocap
- Teleop-station real-time controller (W-RC: 1 kHz aggregation, watchdog, sync-event jig)
- Upper-body retargeting, recorder, four-stage quality gate (PLEM, logging API)
Process Steps
- 1Aggregate operator upper-body motion at 1 kHz and retarget it to the robot
- 2Align six streams to a PTP clock and monitor latency and safety interlocks during the session
- 3Run the four-stage gate on save and register only passing episodes