#6DoFGrasp#RGBD#OnboardInference
Overview
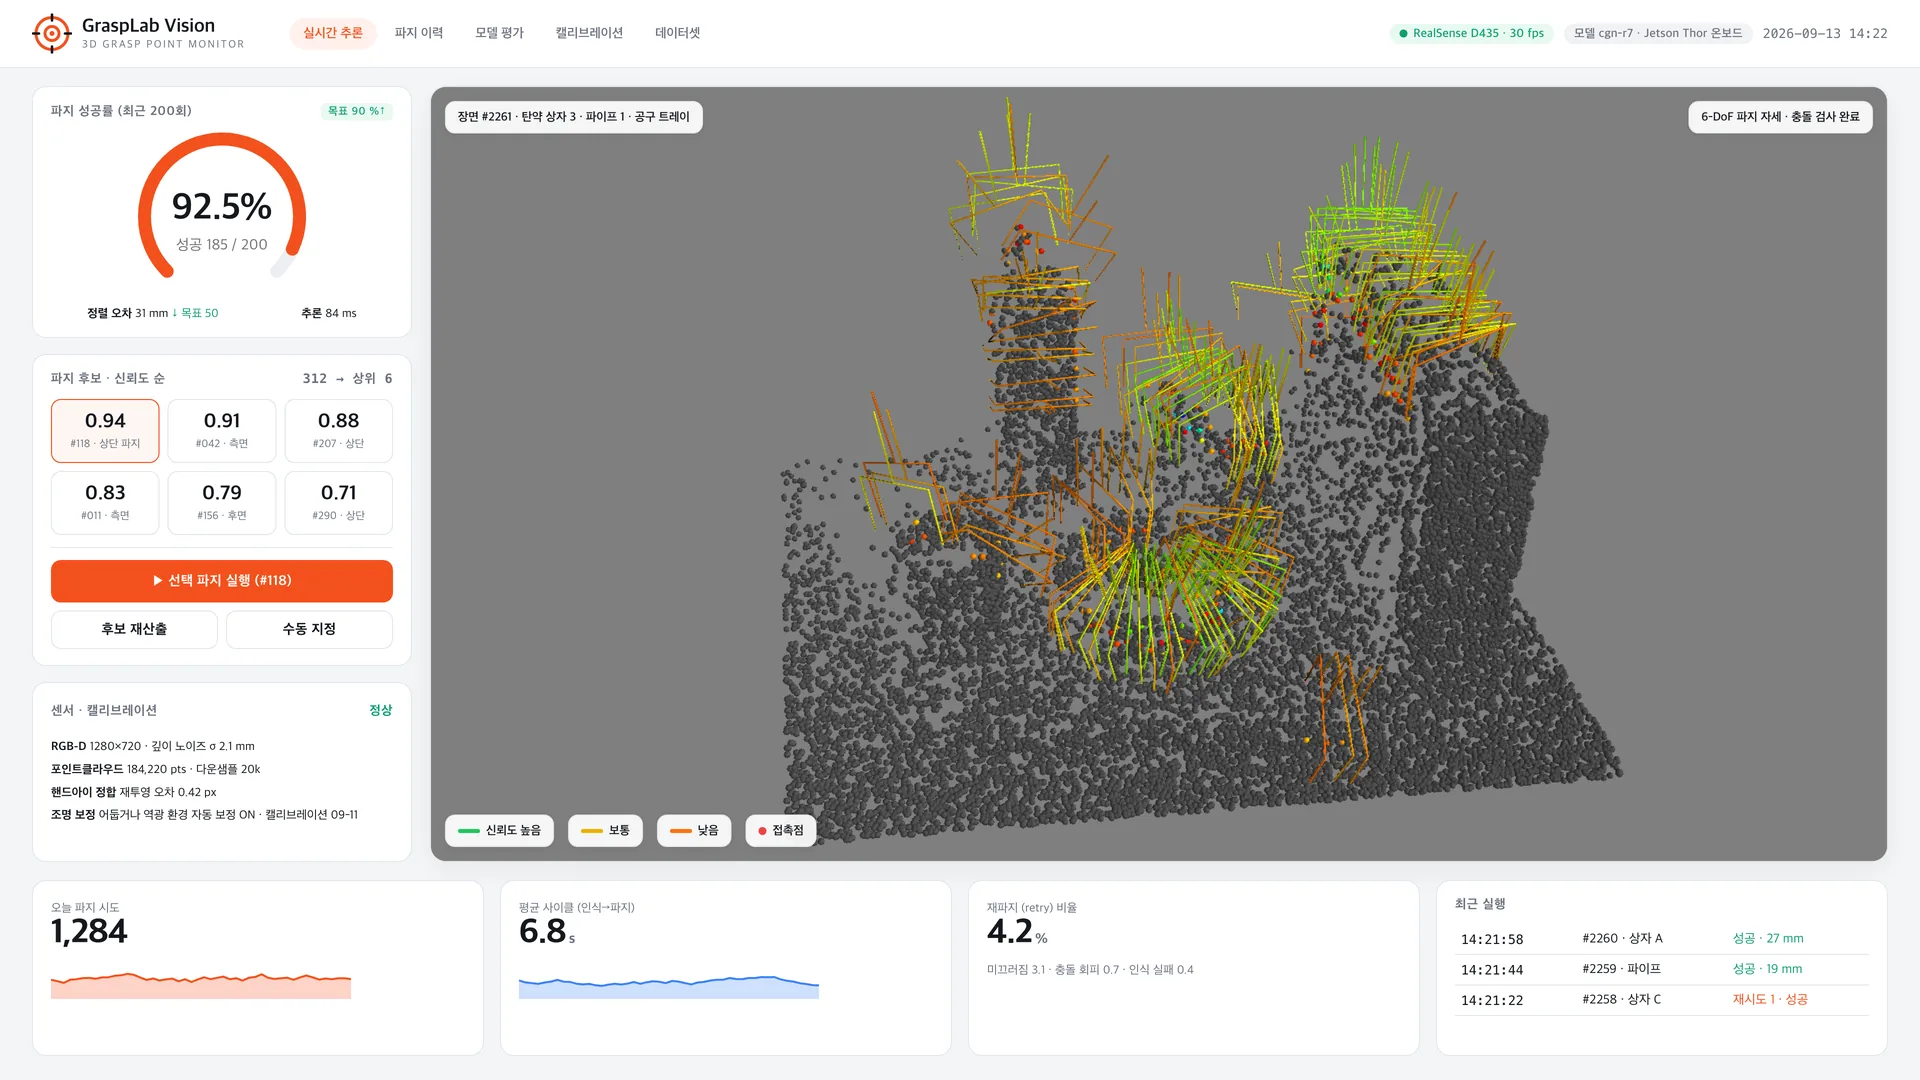
A kitting-cell case that estimates 6-DoF grasp poses from an RGB-D camera and monitors candidate selection, execution, and regrasps.
Project Background & Purpose
The customer kits high-mix parts into compartment buffer trays before they reach the assembly line. Grasp poses were taught by hand for every part change, and failures on reflective or backlit parts ate into cycle time. The project runs a grasp estimator fine-tuned from a public research model on an onboard inference board and executes only after candidate confidence, collision checks, and alignment error are confirmed on the console. Real-time control, the watchdog, and fallback decisions stay with the cell controller; assembly precision is handled by a downstream second-vision step.
Components
- RGB-D camera (1280×720, 30 fps, depth noise σ 2.1 mm), hand-eye calibration at 0.42 px reprojection
- 6-DoF grasp estimator (fine-tuned public research model on a customer-selected onboard inference board)
- Cell real-time controller (W-RC at 1 kHz, watchdog, fallback decision), PLEM
Process Steps
- 1Downsample the 184,220-point cloud to 20 k and generate 312 grasp candidates
- 2Confirm confidence of the top six candidates after collision and approach filtering, then execute
- 3Load into the compartment tray within 50 mm alignment; regrasp on failure and leave assembly precision to second vision