#TaskOrchestration#BehaviorTree#SafetyInterlock
Overview
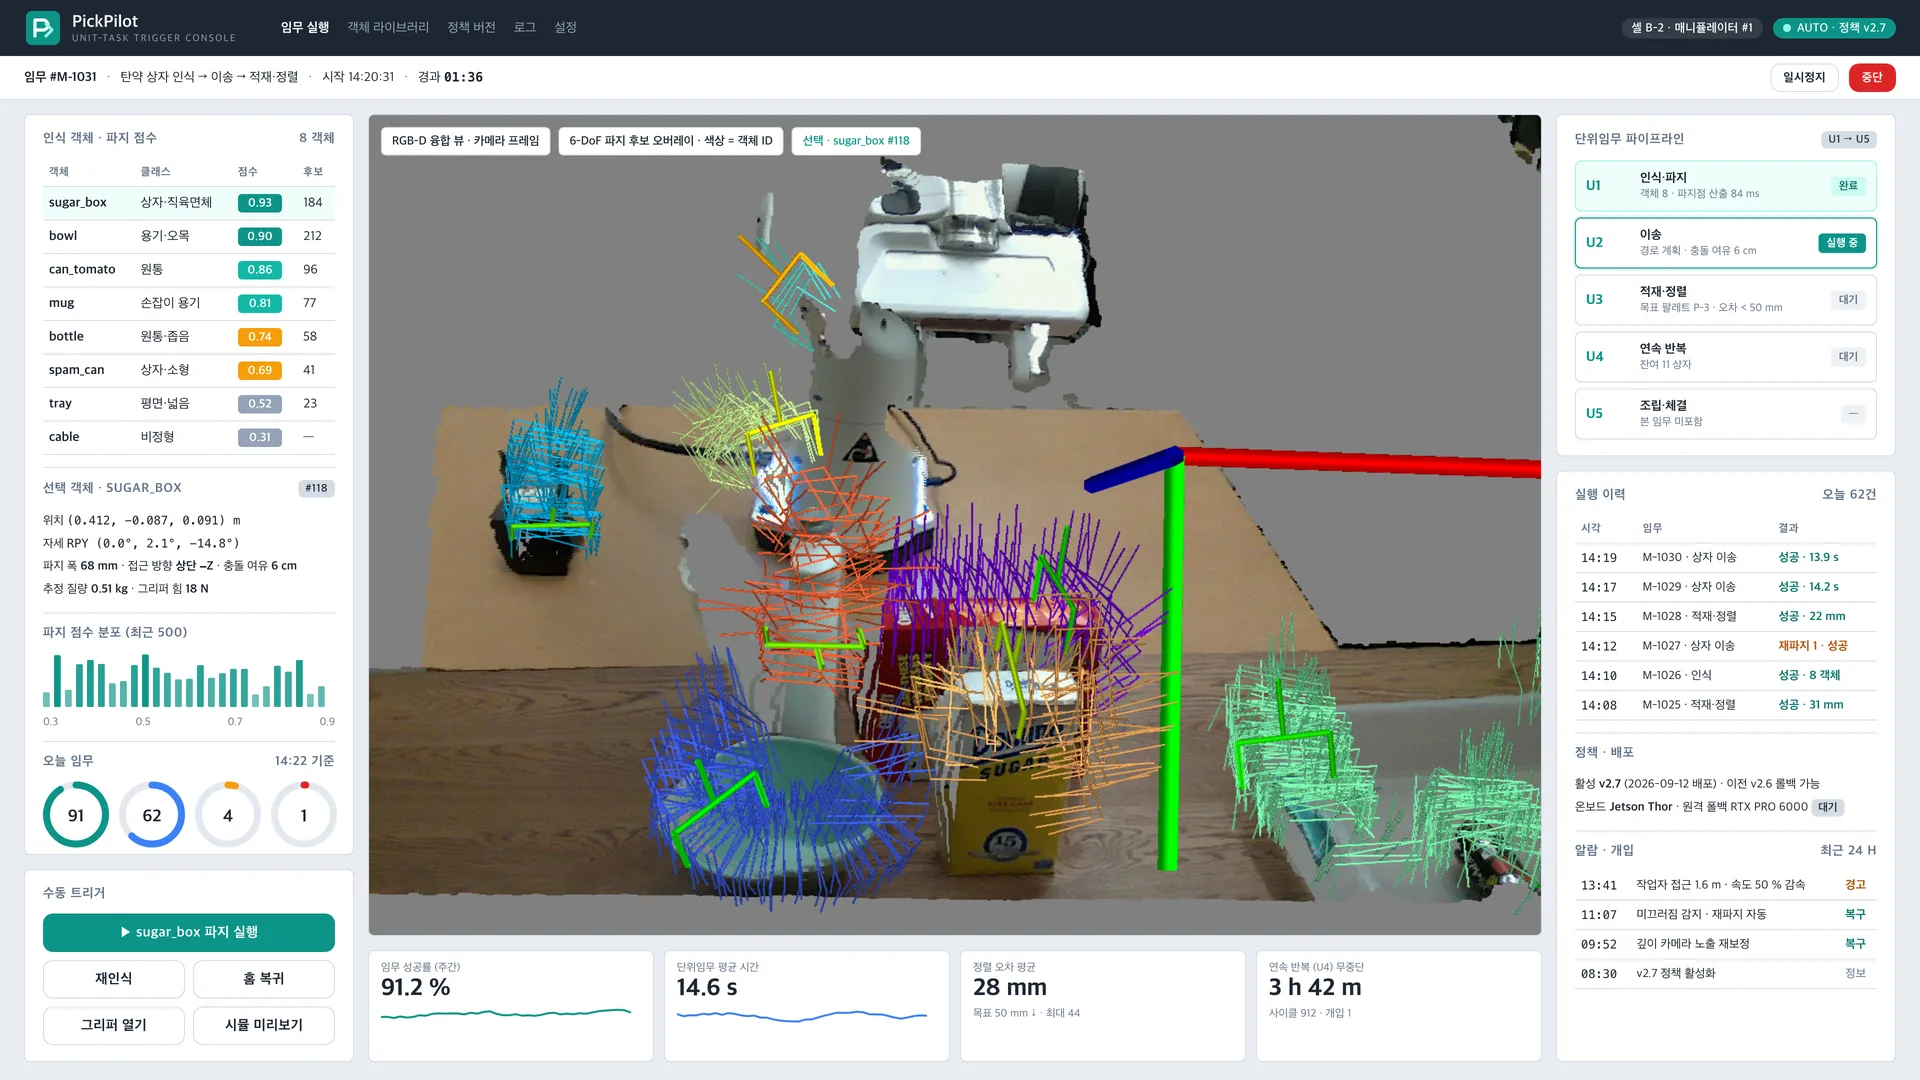
A floor console that runs, intervenes in, and rolls back unit tasks U1 recognize-grasp → U2 transfer → U3 place-align → U4 continuous repeat → U5 assemble-fasten.
Project Background & Purpose
The customer had no console for floor operators to safely run a cell mixing learned policies and scripted skills. Which objects the policy saw and at what score, which unit task was active, and when to intervene were all invisible. The project layers skills on a behavior-tree executor and brings per-object grasp scores, the unit-task pipeline, run history, and alarms onto one screen. Pause, resume, and manual trigger are normal-stop commands; protective and emergency stops are on separate hardwired circuits.
Components
- Behavior-tree executor, skill library (recognize, grasp, transfer, align), path planning
- Cell real-time controller (W-RC at 1 kHz), PLEM, safety PLC hardwired stop circuit
- Policy version operations (active v2.7, rollback v2.6), customer-selected onboard inference board
Process Steps
- 1Triggering a mission runs U1, which recognizes eight objects and shows grasp scores (sugar_box 0.93, etc.)
- 2U2 transfer and U3 place-align confirm alignment within 50 mm; U4 repeats the remaining boxes automatically
- 3Slow to 50 % when a worker comes within 1.6 m, regrasp on slip, and let the operator pause or roll back on anomalies