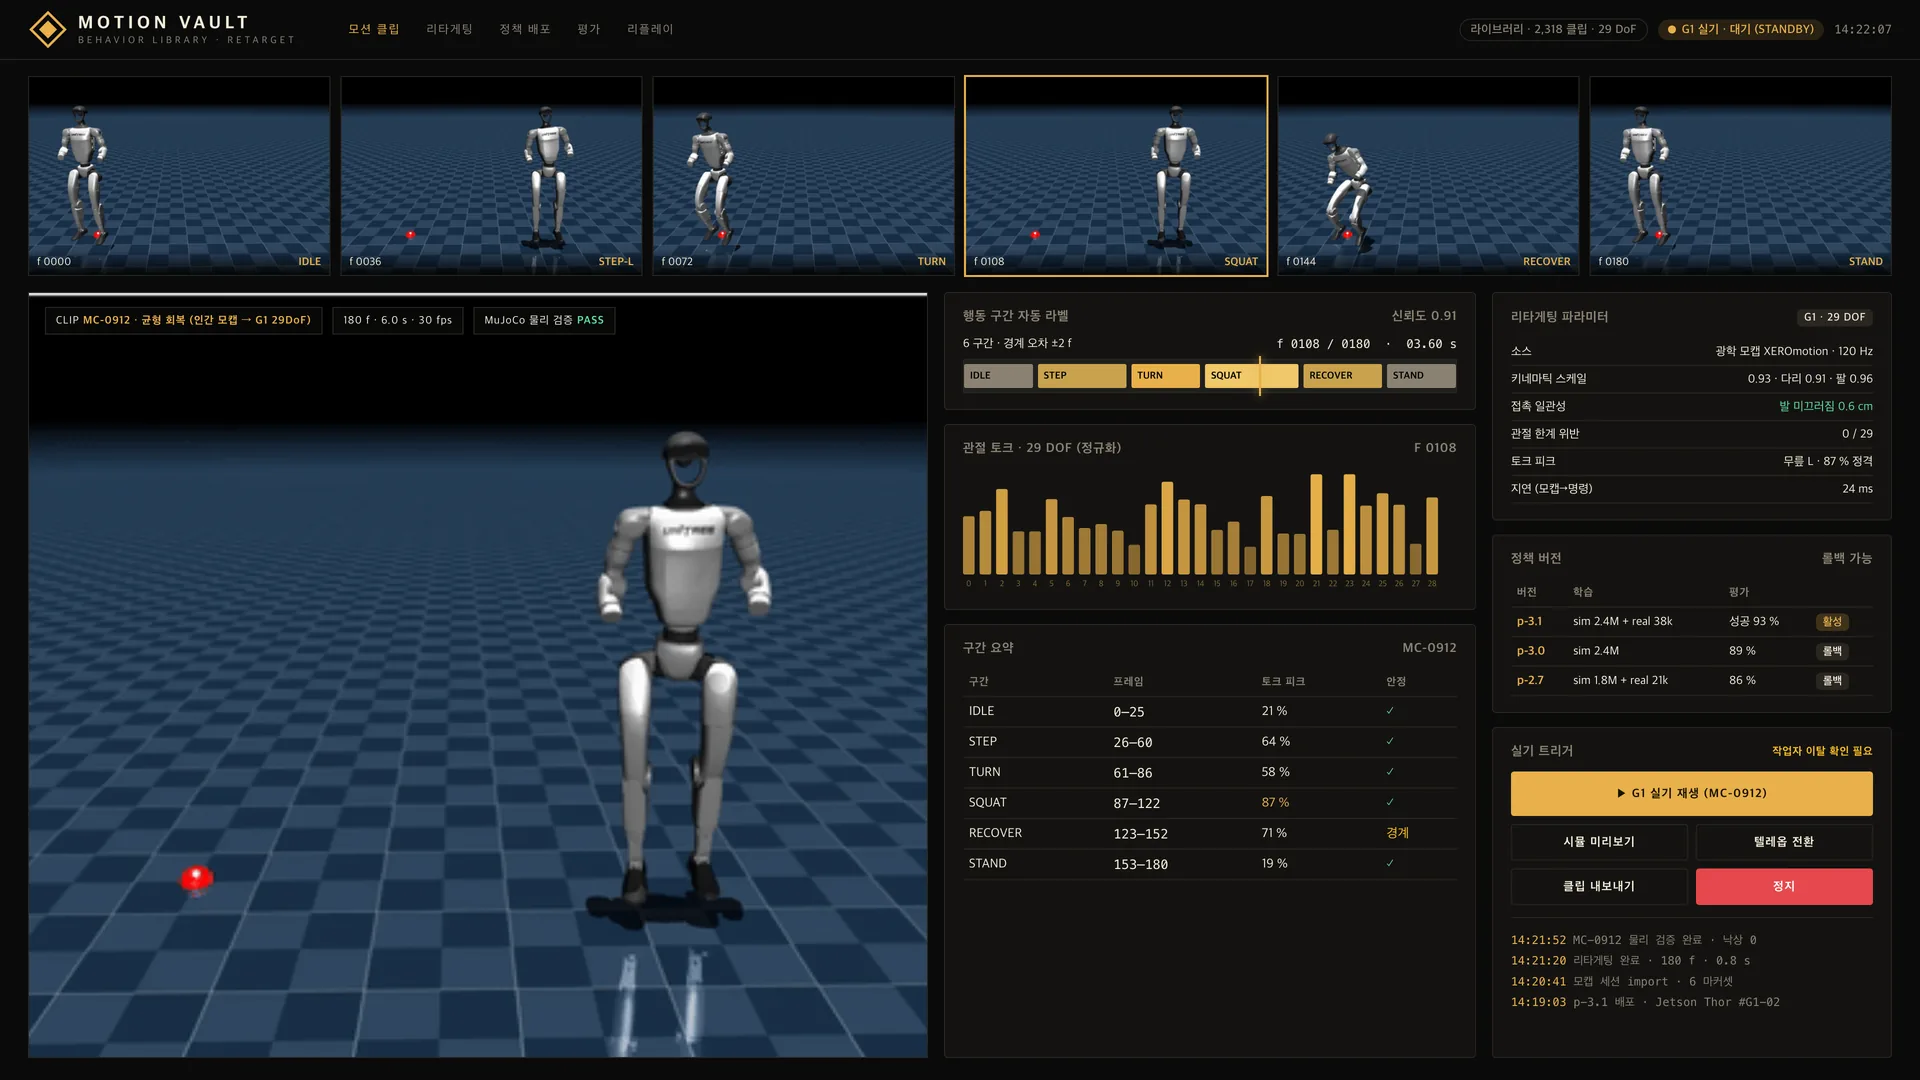
Overview
A console that retargets human mocap to a robot profile, passes it through a physics-validation gate, and registers and replays it from a behavior library.
Project Background & Purpose
Getting a mocap session into the library took four people across retargeting, visual inspection, physics validation, and replay approval. The project makes the robot profile (URDF, arm configuration, hand-retargeting rules, lower-body mapping coefficients, safety limits) the single reference and links import through replay trigger on one console. Walking and balance stay with the robot's built-in controller; our stack sends only upper-body targets and stand-height and velocity commands, while the risk assessment including falls and the stop circuits remain cell-integration deliverables. Reference-tracking policy p-3.1 is owned and trained by the customer; the console displays its simulation-evaluation records.
Components
- 120 Hz optical mocap, batch retargeting pipeline, four-element robot profile
- MuJoCo physics gate (torque limits, contact, falls), automatic segment labeling (6 segments, confidence 0.91)
- Clip library, replay trigger, watchdog logging (PLEM); built-in locomotion controller (customer domain)
Process Steps
- 1Import a mocap clip and batch-retarget it against the profile (180 f in 0.8 s); preview at 24 ms
- 2Validate joint limits, torque peak (knee 87 %), and foot slip in MuJoCo and attach segment labels
- 3Register only gate-passing clips and trigger hardware replay after confirming workers are clear